System and Method for Passive Human Activity Sensing Using Microwave-Oven Emissions as an Opportunistic RF Illuminator with Edge Machine Learning
Abstract
Microwave ovens leak enough 2.45 GHz radio energy to serve as radar illumination. In plain terms: a roughly $20 receiver uses a microwave oven's radio leaks as radar to detect people, falls, and pets, with no added transmitter. Disclosed is a system and method that uses those unintentional emissions, and no dedicated transmitter, as the sole radio-frequency illuminator for passive, device-free human activity sensing in homes. A low-cost receive-only sensing front end (a 2.4 GHz antenna, bandpass filter, and square-law detector, under $20 estimated bill of materials at volume) captures the oven's leakage field during magnetron-on periods. Human motion modulates the received field through multipath fading and Doppler shifts; the direct and reflected waves interfere at the antenna (self-mixing), recovering the motion as baseband amplitude variation. A microcontroller samples this baseband at 2 kSPS, computes micro-Doppler spectrograms via short-time Fourier transform, and classifies activity on-device with a quantized temporal convolutional network (targeting approximately 120 KB and under 25 ms per inference window on an ESP32-S3) using two output heads: an occupancy head (empty, one, two, or three-or-more persons) and an activity head (walking, stationary kitchen activity, standing, seated, lying still, fall event, pet). The system exploits the magnetron's seconds-scale duty-cycle on/off transitions in conventional transformer-based ovens as automatic channel-calibration references, uses door-interlock edges as sensing-session markers, and defines an optional low-duty "sensor mode" in which the oven emits brief full-power pulses (with a fixed dummy load installed) purely for sensing when not cooking. The primary sensing mode adds no radio emissions of its own and captures no audio or video; raw baseband data never leaves the sensor node in the deployed embodiment, and only classified labels and timestamps are reported over the node's pre-certified BLE/Wi-Fi radio.
Field of the Invention
This invention relates to device-free human activity recognition and smart-home sensing, specifically to passive radio-frequency sensing systems that reuse the unintentional electromagnetic emissions of household appliances as opportunistic illuminators, combined with edge-deployed machine learning for activity classification.
Background
Device-free RF sensing detects human presence and activity from perturbations in ambient radio fields, without requiring the person to carry any device. The field's passive-radar lineage long predates Wi-Fi sensing: Griffiths and Baker formalized passive coherent location using broadcast illuminators of opportunity (FM, DVB-T) in 2005, and the community has since demonstrated sensing with FM radio, GSM, and digital television signals. The Wi-Fi-sensing branch then showed what communications transmitters could do indoors. Adib and Katabi demonstrated seeing moving people through walls with Wi-Fi using MIMO interference nulling ("See through walls with WiFi!", ACM SIGCOMM 2013). Pu et al. followed with whole-home gesture recognition from Wi-Fi Doppler signatures, reaching 94% accuracy across nine gestures (ACM MobiCom 2013). Chetty, Smith, and Woodbridge demonstrated through-wall personnel sensing with passive bistatic Wi-Fi radar, reusing existing Wi-Fi transmissions rather than a dedicated radar (IEEE Transactions on Geoscience and Remote Sensing, 2012). Wang et al. extended the idea to device-free activity identification with fine-grained Wi-Fi signatures ("E-eyes", ACM MobiCom 2014), and Zhang et al. pushed cross-domain gesture recognition further ("Widar3.0", IEEE TPAMI 2021).
Every one of these systems assumes the illuminator is a transmitter built for another purpose: a broadcast tower, a cellular base station, a Wi-Fi access point. The home must have that infrastructure, positioned usefully, for sensing to work. Dedicated alternatives exist for homes that do not: microwave Doppler motion-sensor modules such as the RCWL-0516 (a 3.18 GHz self-mixing Doppler module, approximately 20-30 mW transmit power, 5-7 m range) and 60 GHz mmWave presence sensors (e.g., Aqara FP2, approximately $60 retail). These add a new intentional radiator to the home, with associated cost, power draw, and certification; they also require the consumer to buy and install a new device.
Microwave ovens are an overlooked illuminator class. A conventional oven's magnetron emits at a nominal 2.45 GHz in the 2.40-2.50 GHz ISM band at a typical 700-1200 W of cooking power. The cavity is not perfectly sealed: door choke seals, ventilation slots, and the waveguide feedthrough leak a small fraction of this energy. In the United States these unintentional emissions are bounded by the FDA performance standard 21 CFR 1030.10, which limits leakage to 1 mW/cm² at 5 cm from the external surface before purchase and 5 mW/cm² thereafter. That leakage, tiny next to cooking power, is large next to receiver sensitivity: a design-basis reference value of -70 dBm at a 3-meter standoff sits roughly 75 dB above the receiver noise floor in the system's 248 Hz Doppler passband (a power ratio of roughly 30 million; kTB at 248 Hz is approximately -150 dBm, and allowing approximately 5 dB of receiver noise figure puts the floor near -145 dBm). The realized margin varies per installation with the oven's leakage level, the standoff distance, the number and material of intervening walls, the LNA gain, and the diode sensitivity. Per-installation calibration is required, but the link budget closes with margin to spare.
Two further properties make ovens practical opportunistic illuminators. First, they are already present in nearly all U.S. households (the U.S. Energy Information Administration's 2020 Residential Energy Consumption Survey reports that almost all U.S. households have at least one microwave). Second, conventional transformer-based ovens regulate cooking power below 100% by duty-cycling the magnetron on timescales of seconds (for example, approximately 10 seconds on and 10 seconds off at 50% power). The magnetron's turn-on and turn-off edges are sharp and detectable, and they cost nothing to observe. These edges provide automatic channel calibration: the off periods measure the dark channel (receiver noise floor and static multipath), and the on periods are sensing windows against a freshly measured reference.
The gap in the art is a complete, field-deployable system that: (a) uses a microwave oven's unintentional emissions, rather than any communications transmitter, broadcast illuminator, or dedicated radar, as the sole RF illuminator for human activity sensing; (b) receives with a low-cost, receive-only sensing front end that self-mixes direct leakage and reflected paths into a baseband Doppler signal; (c) exploits magnetron duty-cycle edges and door-interlock events as calibration references and session markers; (d) classifies occupancy, activity, falls, and pet-versus-human on an edge microcontroller with no cloud dependency; and (e) defines a low-duty sensor mode that pulses the magnetron briefly for sensing when the oven is not cooking.
Detailed Description
1. Physical Principle: The Oven as an Opportunistic Illuminator
A magnetron is a free-running crossed-field oscillator. Its output is not a clean carrier: the spectrum is several MHz wide with substantial phase noise and spurious sidebands. For this system that noisiness is acceptable, because detection is incoherent: the system measures the amplitude envelope of the leakage field, not its phase.
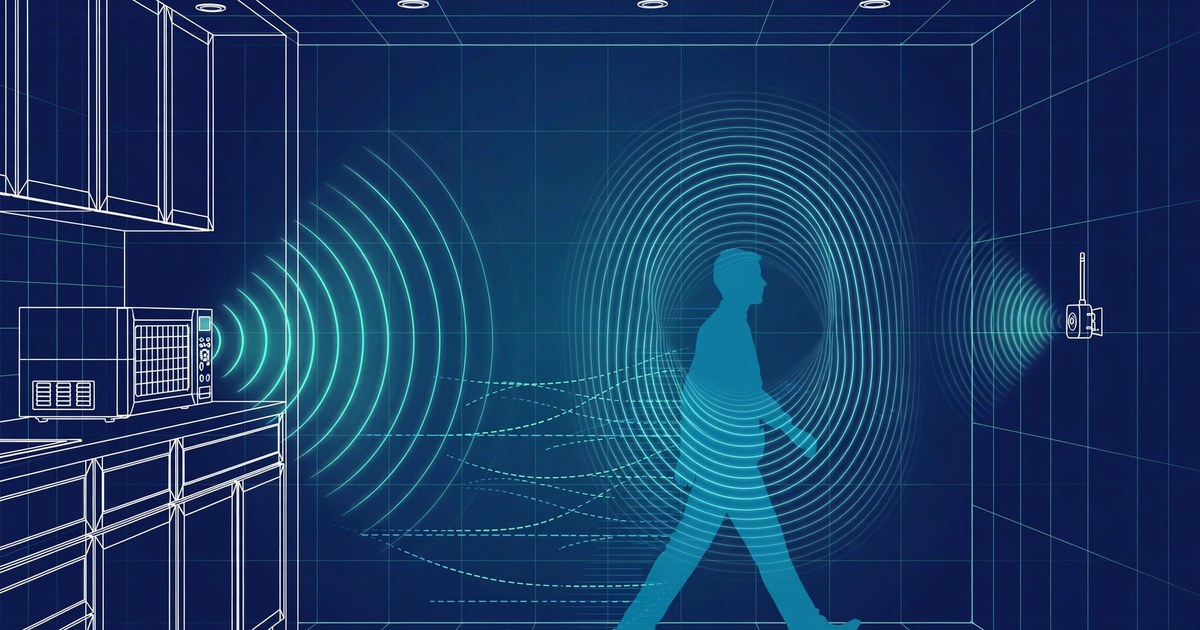
The received signal at a passive antenna is the sum of a direct path (leakage through the oven's seals and vents, arriving line-of-sight or near-line-of-sight) and reflected paths (leakage scattered by walls, furniture, and the human body). Direct and reflected components interfere at the antenna. A moving body changes the reflected path lengths, so the interference product amplitude-modulates at the Doppler frequency of the motion. For carrier wavelength λ = 12.24 cm at 2.45 GHz and a body moving at radial velocity v, the two-way Doppler shift is Δf = 2v/λ. A person walking at 1.4 m/s produces a torso Doppler line at approximately 23 Hz. Swinging limbs move faster relative to the torso and produce micro-Doppler sidebands extending to roughly ±100 Hz for fast limb motion (typical values; these vary with subject and geometry). A fall produces a broadband transient lasting roughly 0.3-0.8 seconds (consistent with fall micro-Doppler durations reported in the radar literature; see Chen 2011 for the general phenomenology, and a production program would validate against fall-specific datasets) as the body's projected area and velocity change rapidly, followed by a collapse of Doppler energy as the body becomes still. A trotting pet produces weaker returns (smaller radar cross-section, order 0.05-0.2 m² versus order 0.3-1.0 m² for an adult human at 2.45 GHz, per standard radar cross-section references such as the Radar Handbook) with a faster cadence (typical 2-4 Hz trot versus typical 1.6-2.2 Hz human step frequency).
The direct path acts as its own local oscillator. Mixing the received composite signal with itself on a square-law detector recovers the Doppler modulation as baseband amplitude variation, the same architecture as the RCWL-0516 Doppler module, except that here the "transmitter" is the oven and the receiver may sit meters away in an adjacent room. Radiation at 2.45 GHz penetrates interior drywall partitions with roughly 3-6 dB of attenuation per wall (consistent with indoor propagation data such as ITU-R P.1238), so a single receiver covers a kitchen and one adjoining room through typical residential construction.
2. Receiver Hardware
Two embodiments are disclosed, differing in cost and in whether full quadrature (IQ) data is captured.
Embodiment A (preferred, envelope detection): A 2.4 GHz printed-circuit-board patch antenna (2-5 dBi gain, estimated $2) feeds a 2.4-2.5 GHz SAW bandpass filter (estimated $1) that selects the ISM band shared by the magnetron, Wi-Fi, and Bluetooth. Wi-Fi and Bluetooth rejection is performed downstream, not by this filter: Wi-Fi bursts are microsecond-to-millisecond scale and are rejected by the baseband bandpass plus the interference template learned during dark windows (see Section 4). The filtered signal passes through a single low-noise amplifier stage (20 dB gain, estimated $2), then a zero-bias Schottky diode detector (estimated $1) that performs square-law self-mixing of the direct and reflected leakage components. The detector output is AC-coupled into a baseband operational amplifier (estimated $1) with a 2-250 Hz passband, then digitized by the microcontroller's 12-bit ADC at 2 kSPS. With an ESP32-S3 module (estimated $4), power supply (estimated $2), and enclosure (estimated $3), the complete sensor node is under $20 estimated bill of materials.
*Detector operating-point analysis (design calculation; verify per installation):* Taking the design-basis reference leakage of -70 dBm at the antenna and 20 dB of LNA gain, the diode sees approximately -50 dBm. A zero-bias Schottky diode of the HSMS-2850 class has a tangential signal sensitivity near -54 dBm and operates in its square-law region below roughly -20 dBm, so -50 dBm sits in the square-law region with small margin; installations with weaker leakage add a second LNA stage. A walking person modulates the reflected paths by an estimated ±3-6 dB against the direct-path carrier, producing baseband ripple on the order of millivolts at the detector output; 40 dB of baseband gain brings this to roughly 100-300 mV peak-to-peak at the ADC. Firmware automatic gain control switches between two baseband gain ranges based on the measured envelope level, accommodating ovens and standoffs that differ from the reference case.
Embodiment B (IQ capture, development and high-fidelity configuration): A 2.4 GHz antenna feeds a 2.4 GHz-to-70 MHz downconverter module (estimated $25) whose output is sampled by an RTL-SDR-class software-defined radio (estimated $35) at 2.4 MSPS. IQ samples are processed on a Raspberry Pi-class host or streamed to the edge classifier after decimation. This embodiment captures true micro-Doppler spectra with higher fidelity and supports multi-antenna angle-of-arrival extensions, at a node cost under $80 excluding the host computer. IQ streaming off the node is a development configuration; the deployed configuration reports only classified labels (see Section 7).
In both embodiments the sensing front end is strictly receive-only: it emits no RF illumination. The node's only intentional emissions are its BLE/Wi-Fi reporting radio, which operates under the ESP32-S3 module's existing pre-certified FCC Part 15 Subpart C grant; the sensing circuitry itself is an unintentional radiator under Part 15 Subpart B.
3. Signal Processing Pipeline
The pipeline runs entirely on the sensor node's microcontroller in Embodiment A:
- Acquisition: The ADC samples the baseband Doppler signal at 2 kSPS with 12-bit resolution. A 2-second ring buffer holds 4,000 samples (8 KB).
- Preprocessing: A DC-notch filter removes the static direct-path component. A 4th-order IIR bandpass (2-250 Hz) rejects mains hum (50/60 Hz and harmonics are explicitly notched), HVAC vibration, and sub-2 Hz structural vibration. Wi-Fi bursts, which are broadband in this baseband, are attenuated here and further suppressed by the dark-window interference template.
- Time-frequency transform: A 256-point short-time Fourier transform with 50% overlap (128-sample hop) and Hann windowing produces a micro-Doppler spectrogram at 15.625 frames per second. Bins covering 2-250 Hz are retained (32 bins).
- Feature extraction: Per-frame features include total Doppler energy, spectral centroid, spectral bandwidth, the torso Doppler track (strongest peak below 40 Hz), limb micro-Doppler energy ratio (energy above 40 Hz divided by total energy), and zero-crossing rate of the raw baseband.
- Classification: A shared 1D temporal-convolutional backbone (four convolutional layers with 32/64/64/128 filters, kernel size 5, followed by global average pooling) feeds two softmax heads: an occupancy head (empty, one person, two persons, three or more persons) and an activity head (walking, stationary kitchen activity, standing, seated, lying still, fall event, pet). Occupant counting saturates at "three or more" because the Doppler tracks of additional bodies merge in a single-antenna spectrogram; this is a stated limitation, not a failure mode. Each head ingests sequences of 32 consecutive feature frames (approximately 2.05 seconds of context), and inference runs with a stride of 16 frames (approximately 1.02 seconds). The model is quantized to INT8 and deployed via TensorFlow Lite Micro, targeting approximately 120 KB of flash and under 25 ms inference per window on an ESP32-S3 at 240 MHz (design targets; Claim 6 states a 200 KB upper bound to allow headroom for larger backbones). All window, stride, threshold, and gain constants are tunable firmware parameters with the defaults stated here.
- Post-processing: Per-window posteriors are smoothed with an exponential moving average over 8 windows (approximately 8.2 seconds). The fall-event class bypasses this smoothing: the raw per-window fall posterior is compared against its threshold directly, so the 8.2-second average cannot dilute the 0.3-0.8 second transient. Fall declaration uses a deterministic latch state machine, not a learned sequence model: a fall is declared when the activity head reports the fall-event class (broadband transient of 0.3-0.8 s followed by Doppler energy collapse) in two consecutive inference windows (approximately 2.05 seconds of sustained signature). The fall state latches until the activity head reports walking, standing, or seated for 10 consecutive seconds (approximately 10 windows) or a manual reset is received via the home hub.
Training data is collected by recording synchronized baseband Doppler and labeled video in homes where every occupant has given informed consent as described in Section 7; video is used only for labeling, and the shipped product contains no camera. The training protocol targets at least 20 homes, 200 hours of recordings, and 50 subjects across ages and mobility levels, including at least 500 staged falls performed by trained volunteers on crash mats (natural kitchen recordings contain essentially no real falls, so the ≥95% fall-sensitivity design target is validated against staged events); these are design targets for a production validation program. Data augmentation includes synthetic multipath fading, additive noise at the measured dark-channel floor, and time-warping of gait signatures.
4. Duty-Cycle Calibration and Session Markers
Conventional transformer-based microwave ovens regulate power below 100% by switching the magnetron on and off over a control interval of roughly 10-30 seconds (for example, approximately 10 seconds on and 10 seconds off at 50% power on many models). The receiver detects these transitions as step changes in the 2.45 GHz envelope:
- Magnetron-off periods are dark calibration windows. The system measures the receiver noise floor, estimates the static multipath baseline, updates an adaptive clutter map (a stored profile of the unchanging reflected paths), and trains the interference-rejection template: any Doppler-band energy observed during off periods is, by definition, interference (for example, a neighbor's oven or residual Wi-Fi leakage), and its spectral shape is subtracted from subsequent on-period observations. The template is re-estimated opportunistically during any magnetron-off period, not only during scheduled dark windows, so it does not go stale against daytime interference patterns (for example, a neighbor's oven used at dinner time).
- Magnetron-on edges re-arm the sensing pipeline with a fresh reference. The first 500 ms after turn-on (a tunable default) are discarded as magnetron warm-up transient before classification resumes.
- Door-interlock events cut magnetron power within milliseconds of the door latch releasing. The receiver sees a near-instantaneous envelope collapse, which the system uses as a sensing-session boundary marker: the occupant has just interacted with the oven, so the prior probability of the stationary-kitchen-activity class is raised for the following 60 seconds (a tunable default).
- Continuous-emission fallback: A conventional oven at 100% power and an inverter-based oven (which varies magnetron drive continuously rather than duty-cycling) both produce no on/off edges. For these cases the system falls back to door-interlock events plus scheduled dark windows (user-configured nightly quiet hours used for clutter-map refresh). Note that every cooking session begins with a magnetron turn-on edge, which provides a timing reference for the session; the dark measurement for that session comes from the idle period immediately before it, when the magnetron is off.
5. Sensor Mode: Pulsed Illumination Without Cooking
When the oven is idle, the user may enable an optional sensor mode. In this mode the oven's controller drives the magnetron at a full-power override in brief pulses, for example 2 seconds every 5 minutes, purely to illuminate the room for sensing. Full-power override is required for deterministic emission: at reduced power settings the oven's own seconds-scale duty cycling could place a commanded short pulse inside an off window, so the pulse must command the magnetron unconditionally.
Because the cavity is empty during sensor mode, a fixed dummy load is required: a sealed, permanently mounted water-equivalent vessel (approximately 250 mL) absorbs the pulse energy. A 2-second pulse at approximately 1100 W input deposits roughly 2200 J, raising the dummy load by approximately 2 K per pulse; the 5-minute interval provides ample cooling. Running a magnetron into an empty cavity without such a load reflects power back into the tube and is the standard do-not-run-empty hazard; the dummy load is a mandatory part of the sensor-mode embodiment, not an accessory.
Energy cost is modest: 2 seconds at approximately 1100 W input every 300 seconds averages 7.3 W, or approximately 0.18 kWh per day of continuous sensor-mode operation (on the order of a few cents of electricity per day at typical residential rates). Relay endurance is the binding constraint on conventional transformer-based ovens: 288 switching cycles per day against typical power-relay endurance ratings above 100,000 cycles (consult the specific relay datasheet) gives roughly one year of sensor-mode service before relay replacement, which is disclosed to the user at enablement time. Inverter-based ovens have no relay wear concern and may pulse more frequently.
Sensor mode is opt-in, disabled by default, indicated by a distinct LED blink pattern on the oven, and presented with a household notice (see Section 7) so that all co-occupants are aware the oven periodically emits.
6. Multi-Illuminator Fusion and Oven-Off Coverage
A home may contain more than one microwave oven, or the oven may be off for long stretches. Two extensions cover these cases:
- Multi-oven arbitration (Embodiment B only): Each sensor node continuously estimates the received envelope from each detectable oven. Ovens are distinguished by their magnetron spectral fingerprints: center-frequency offsets of ±2-5 MHz between units (a design-basis range, to be characterized per oven) and distinct warm-up transient shapes. Frequency resolution is available only in the IQ-capture embodiment, so this arbitration scheme is scoped to Embodiment B. The node locks to the strongest illuminator and re-locks when the envelope ranking changes.
- Wi-Fi CSI fallback: An optional ESP32 Wi-Fi channel-state-information tap runs a lightweight variance-based occupancy detector. When no oven is active and sensor mode is disabled, the system falls back to this coarser detector (occupancy only, no activity classification). Classification posteriors from the two modalities are fused by weighted averaging when both are available, with weights proportional to each modality's measured signal-to-noise ratio.
Coverage limitations: without sensor mode or the CSI fallback, the system senses only while the magnetron runs, which for typical households is minutes per day concentrated around meals. Continuous coverage requires the opt-in sensor mode or the fallback.
7. Privacy, Safety, and Dual-Use Properties
The sensing front end is receive-only and adds no RF illumination to the home; the node's only intentional emissions are its pre-certified BLE/Wi-Fi reporting radio. The deployed sensing embodiments capture no audio and no video; labeled video is captured only under the training protocol described in Section 3. The 2-250 Hz baseband contains motion modulation only; it carries no speech content and cannot form optical images.
In the deployed configuration (Embodiment A, and Embodiment B in its deployed mode), raw baseband data never leaves the sensor node: only classified labels (occupancy count, activity class, fall alerts) and timestamps are transmitted to the home hub. IQ streaming off the node exists only as a development configuration for model training and field debugging.
Two limitations of these privacy properties are stated explicitly. First, micro-Doppler gait signatures can be identifying across sessions in the research literature; labels plus timestamps reveal household routines. Mitigations in this design: all inference is on-device by default, label history is kept on a 24-hour rolling buffer unless the user opts into longer retention, and no raw waveforms are retained after classification. Second, through-wall occupancy sensing is dual-use: the same capability that detects a fallen elder can surveil tenants, partners, or employees, and this applies to the primary passive embodiment as well as to sensor mode, since a single receiver covers a kitchen and one adjoining room whenever anyone cooks. Mitigations in this design: deployment of the primary embodiment requires household-level notice, presented in the companion app at setup, disclosing the sensing capability and its through-wall range; the sensor node carries a visible status LED that is lit whenever the sensing pipeline is armed; and sensor mode additionally requires household-level opt-in. An installer enabling either mode is not consent from co-occupants, tenants, or guests, and the design does not pretend otherwise.
Training-data integrity is handled separately from shipped-product privacy. The training protocol records synchronized baseband Doppler and labeled video only in homes where every occupant has given informed consent (guardians consent for minors); labeling video is retained no longer than 30 days after labeling is complete and is then destroyed by cryptographic erasure or physical destruction of the media; baseband recordings are retained only within the scope of the consent given.
The microwave oven itself is unmodified in the primary sensing embodiment. Sensor mode is implemented as an oven-controller firmware feature provided by the oven manufacturer; any unit operating in sensor mode should be re-verified to remain within the 21 CFR 1030.10 power-density limits, because pulsed empty-cavity operation with a dummy load differs from the originally tested cooking profile, and the standard's service-procedure provisions contemplate exactly this kind of change.
8. Figures Description
- Figure 1: System architecture showing a microwave oven emitting unintentional 2.45 GHz leakage, direct and human-reflected propagation paths through a kitchen and dining area, and a wall-mounted receive-only sensor node with antenna, RF front end, and edge-classifier microcontroller.
- Figure 2: Baseband Doppler waveforms and micro-Doppler spectrograms for the seven activity-head classes (walking, stationary kitchen activity, standing, seated, lying still, fall event, pet), annotated with torso Doppler tracks and limb micro-Doppler sidebands.
- Figure 3: Magnetron duty-cycle envelope over a 60-second window at 50% power, marking on/off edges, dark calibration windows, the warm-up transient exclusion zone, and a door-interlock event.
- Figure 4: Sensor-mode timing diagram showing 2-second full-power illumination pulses every 5 minutes, the dummy-load thermal budget, average-power computation, and relay-cycle budget.
- Figure 5: Signal processing pipeline block diagram: antenna, SAW filter, LNA, diode detector, ADC at 2 kSPS, 256-point STFT at 50% overlap (15.625 fps), feature extraction, quantized two-head temporal CNN (32-frame context, 16-frame stride), posterior smoothing, and the fall-latch state machine.
Claims
- A system for passive human activity sensing, comprising: a microwave oven comprising a magnetron producing unintentional electromagnetic emissions in the 2.40-2.50 GHz band during magnetron operation; and a sensor node comprising a 2.4 GHz antenna, a bandpass filter, a square-law detector that self-mixes direct-path leakage emissions with human-body-reflected emissions to produce a baseband Doppler signal, an analog-to-digital converter sampling the baseband Doppler signal in a 2-250 Hz passband, and a microcontroller; wherein the microcontroller computes micro-Doppler spectrograms from the baseband Doppler signal and classifies human activity using an on-device machine learning model, and wherein the human-activity sensing is performed without any dedicated radio-frequency illuminator transmitter.
- The system of claim 1, wherein the square-law detector is a zero-bias Schottky diode, or a logarithmic RF power detector biased for square-law detection at the received power levels, and wherein the baseband Doppler signal is sampled at 1-4 kSPS.
- The system of claim 1, further comprising a duty-cycle calibration module that detects magnetron on/off transitions in a received emission envelope, uses magnetron-off periods as dark calibration windows to measure receiver noise floor, update a static multipath clutter map, and train an interference-rejection template, and discards a warm-up transient interval following each magnetron-on edge before resuming classification; and wherein, when no magnetron on/off transitions are detected over a configurable interval, the module falls back to door-interlock events and scheduled dark windows for calibration.
- The system of claim 1, further comprising a session-marker module that detects door-interlock events as near-instantaneous collapses of a received emission envelope and raises the prior probability of a stationary-kitchen-activity class for a configurable period following each detected event.
- The system of claim 1, wherein a controller of the microwave oven is configured with an opt-in sensor mode that emits periodic brief full-power magnetron pulses when the oven is not cooking, the pulses serving solely as illumination for the sensing system, and wherein a fixed dummy load is mounted in the oven cavity to absorb the pulse energy.
- The system of claim 1, wherein the on-device machine learning model is a quantized temporal convolutional network occupying less than 200 KB of flash memory, comprising a shared convolutional backbone and two softmax output heads: an occupancy head classifying empty, one person, two persons, or three or more persons, and an activity head classifying walking, stationary kitchen activity, standing, seated, lying still, fall event, or pet.
- The system of claim 6, further comprising a fall-detection latch that declares a fall upon the activity head reporting the fall-event class, defined as a broadband Doppler transient of 0.3-0.8 seconds followed by Doppler energy collapse, in two consecutive inference windows, and that maintains the fall state until the activity head reports walking, standing, or seated for 10 consecutive seconds or a manual reset is received.
- The system of claim 6, further comprising pet-versus-human discrimination based on estimated radar cross-section and gait cadence extracted from the micro-Doppler spectrograms.
- The system of claim 1, further comprising, in an IQ-capture embodiment, a multi-oven arbitration module that distinguishes multiple microwave ovens by magnetron spectral fingerprints comprising center-frequency offsets and warm-up transient shapes, and that locks sensing to the microwave oven producing the strongest received emissions.
- A method for passive human activity sensing comprising: receiving, at a sensor node, unintentional 2.40-2.50 GHz electromagnetic emissions of a microwave oven comprising a magnetron during magnetron operation; self-mixing direct-path and reflected-path components of the emissions to recover a baseband Doppler signal; computing micro-Doppler spectrograms from the baseband signal; classifying human occupancy and activity from the spectrograms using an edge-deployed quantized neural network with separate occupancy and activity output heads; calibrating against dark-channel measurements taken during magnetron-off duty-cycle periods; and reporting from the sensor node only classified activity labels and timestamps.
- The system of claim 1, further comprising a Wi-Fi channel-state-information fallback module that performs variance-based occupancy detection when no microwave oven is active, and that fuses its occupancy posteriors with the output of the on-device machine learning model by weighted averaging proportional to each modality's measured signal-to-noise ratio.
Prior Art References
- H. D. Griffiths and C. J. Baker, "Passive coherent location radar systems. Part 1: Performance prediction," IEE Proceedings Radar, Sonar and Navigation, 152(3):153-159, June 2005 — passive radar using broadcast illuminators of opportunity.
- F. Adib and D. Katabi, "See through walls with WiFi!", ACM SIGCOMM 2013, pp. 75-86. DOI: 10.1145/2534169.2486039
- Q. Pu, S. Gupta, S. Gollakota, and S. Patel, "Whole-home gesture recognition using wireless signals", ACM MobiCom 2013, pp. 27-38.
- K. Chetty, G. Smith, and K. Woodbridge, "Through-the-wall sensing of personnel using passive bistatic wifi radar at standoff distances", IEEE Transactions on Geoscience and Remote Sensing, 50(4):1218-1226, 2012.
- Y. Wang et al., "E-eyes: device-free location-oriented activity identification using fine-grained wifi signatures", ACM MobiCom 2014.
- Y. Zhang et al., "Widar3.0: Zero-effort cross-domain gesture recognition with Wi-Fi", IEEE Transactions on Pattern Analysis and Machine Intelligence, 2021.
- V. C. Chen, "The Micro-Doppler Effect in Radar", Artech House, 2011 — micro-Doppler phenomenology including fall signatures.
- U.S. FDA, 21 CFR 1030.10, "Microwave ovens", performance standard for microwave oven emissions (1 mW/cm² at 5 cm pre-purchase, 5 mW/cm² thereafter).
- U.S. Energy Information Administration, 2020 Residential Energy Consumption Survey (RECS): almost all U.S. households have at least one microwave. https://www.eia.gov/todayinenergy/detail.php?id=53439
- Pratica speed-oven engineering reference: microwave power percentage as magnetron duty cycle over a control interval (e.g., 50% ≈ 15 s on per 30 s interval). https://www.praticausa.com/blog/speed-oven-power-levels
- RCWL-0516 microwave Doppler radar sensor module (3.18 GHz self-mixing Doppler architecture): reference design for single-antenna self-mixing motion detection. https://www.edn.com/get-started-microwave-radar-motion-sensor/
- ITU-R P.1238, propagation data for indoor radio planning: interior wall attenuation values at 2.4 GHz.
- M. Skolnik (ed.), "Radar Handbook", McGraw-Hill: order-of-magnitude human-body radar cross-sections at microwave frequencies.
- TensorFlow Lite for Microcontrollers: on-device ML runtime for quantized neural networks.
- Espressif ESP32-S3 SoC: microcontroller with vector DSP extensions used for edge inference.
- LITF-PA-2026-180, "System and Method for Continuous Microwave Oven Door-Seal RF Leakage Monitoring Using Existing Home WiFi Infrastructure as a Distributed Channel-State Sensor": uses home Wi-Fi as a sensor to monitor oven leakage for appliance safety; does not use the oven as an illuminator for human activity sensing.
- LITF-PA-2026-163, "System and Method for Microwave Oven Magnetron Health Estimation via Mains Current Signature Analysis": estimates magnetron health from electrical current signatures; does not perform RF sensing of human activity.
Implementation Notes
A minimal viable prototype can be assembled from off-the-shelf parts: a 2.4 GHz PCB antenna, a 2.4 GHz SAW filter, a 20 dB LNA, a zero-bias Schottky diode (e.g., HSMS-2850 class) or logarithmic detector, an op-amp baseband stage with dual-range gain, and an ESP32-S3 development board, for under $40 in single-unit quantities (under $20 estimated at volume).
Bring-up procedure: place the receiver 2-4 meters from the oven. First record the dark-channel baseline with the oven off and the room empty (receiver noise floor and static multipath). Then run the oven at 100% power with a water load and the room empty to record the illuminated-channel baseline (direct-path level and clutter). Then have a person walk a marked path to verify the torso Doppler line near 2v/λ (approximately 23 Hz at 1.4 m/s walking speed). Magnetron center frequencies drift ±2-5 MHz between ovens and with temperature; the SAW filter's 100 MHz passband absorbs this drift without retuning.
Expected performance envelope (design targets for a production validation program, not measured results): detection range 2-8 m through up to two drywall partitions; fall-event sensitivity target ≥95% with ≤1 false alarm per week; fall-to-alert latency under 5 s from signature completion; occupant counting saturates at three-or-more persons; sensor-node power draw approximately 0.5 W active. Minimum usable leakage is set per installation during the illuminated-channel baseline step; ovens at the low end of the 21 CFR 1030.10 range may need the second LNA stage or shorter standoff.
Regulatory note: the sensor node's sensing circuitry is an unintentional radiator under FCC Part 15 Subpart B; its BLE/Wi-Fi reporting radio operates under the radio module's existing pre-certified Part 15 Subpart C grant. The oven itself is unmodified in the primary sensing embodiment. Sensor mode is a manufacturer firmware feature; re-verify the unit against the 21 CFR 1030.10 power-density limits after enabling it.